Explore projects by research theme. Select a category to show matching projects, or choose All projects to browse the full collection.
TacLight: soft optical tactile sensing
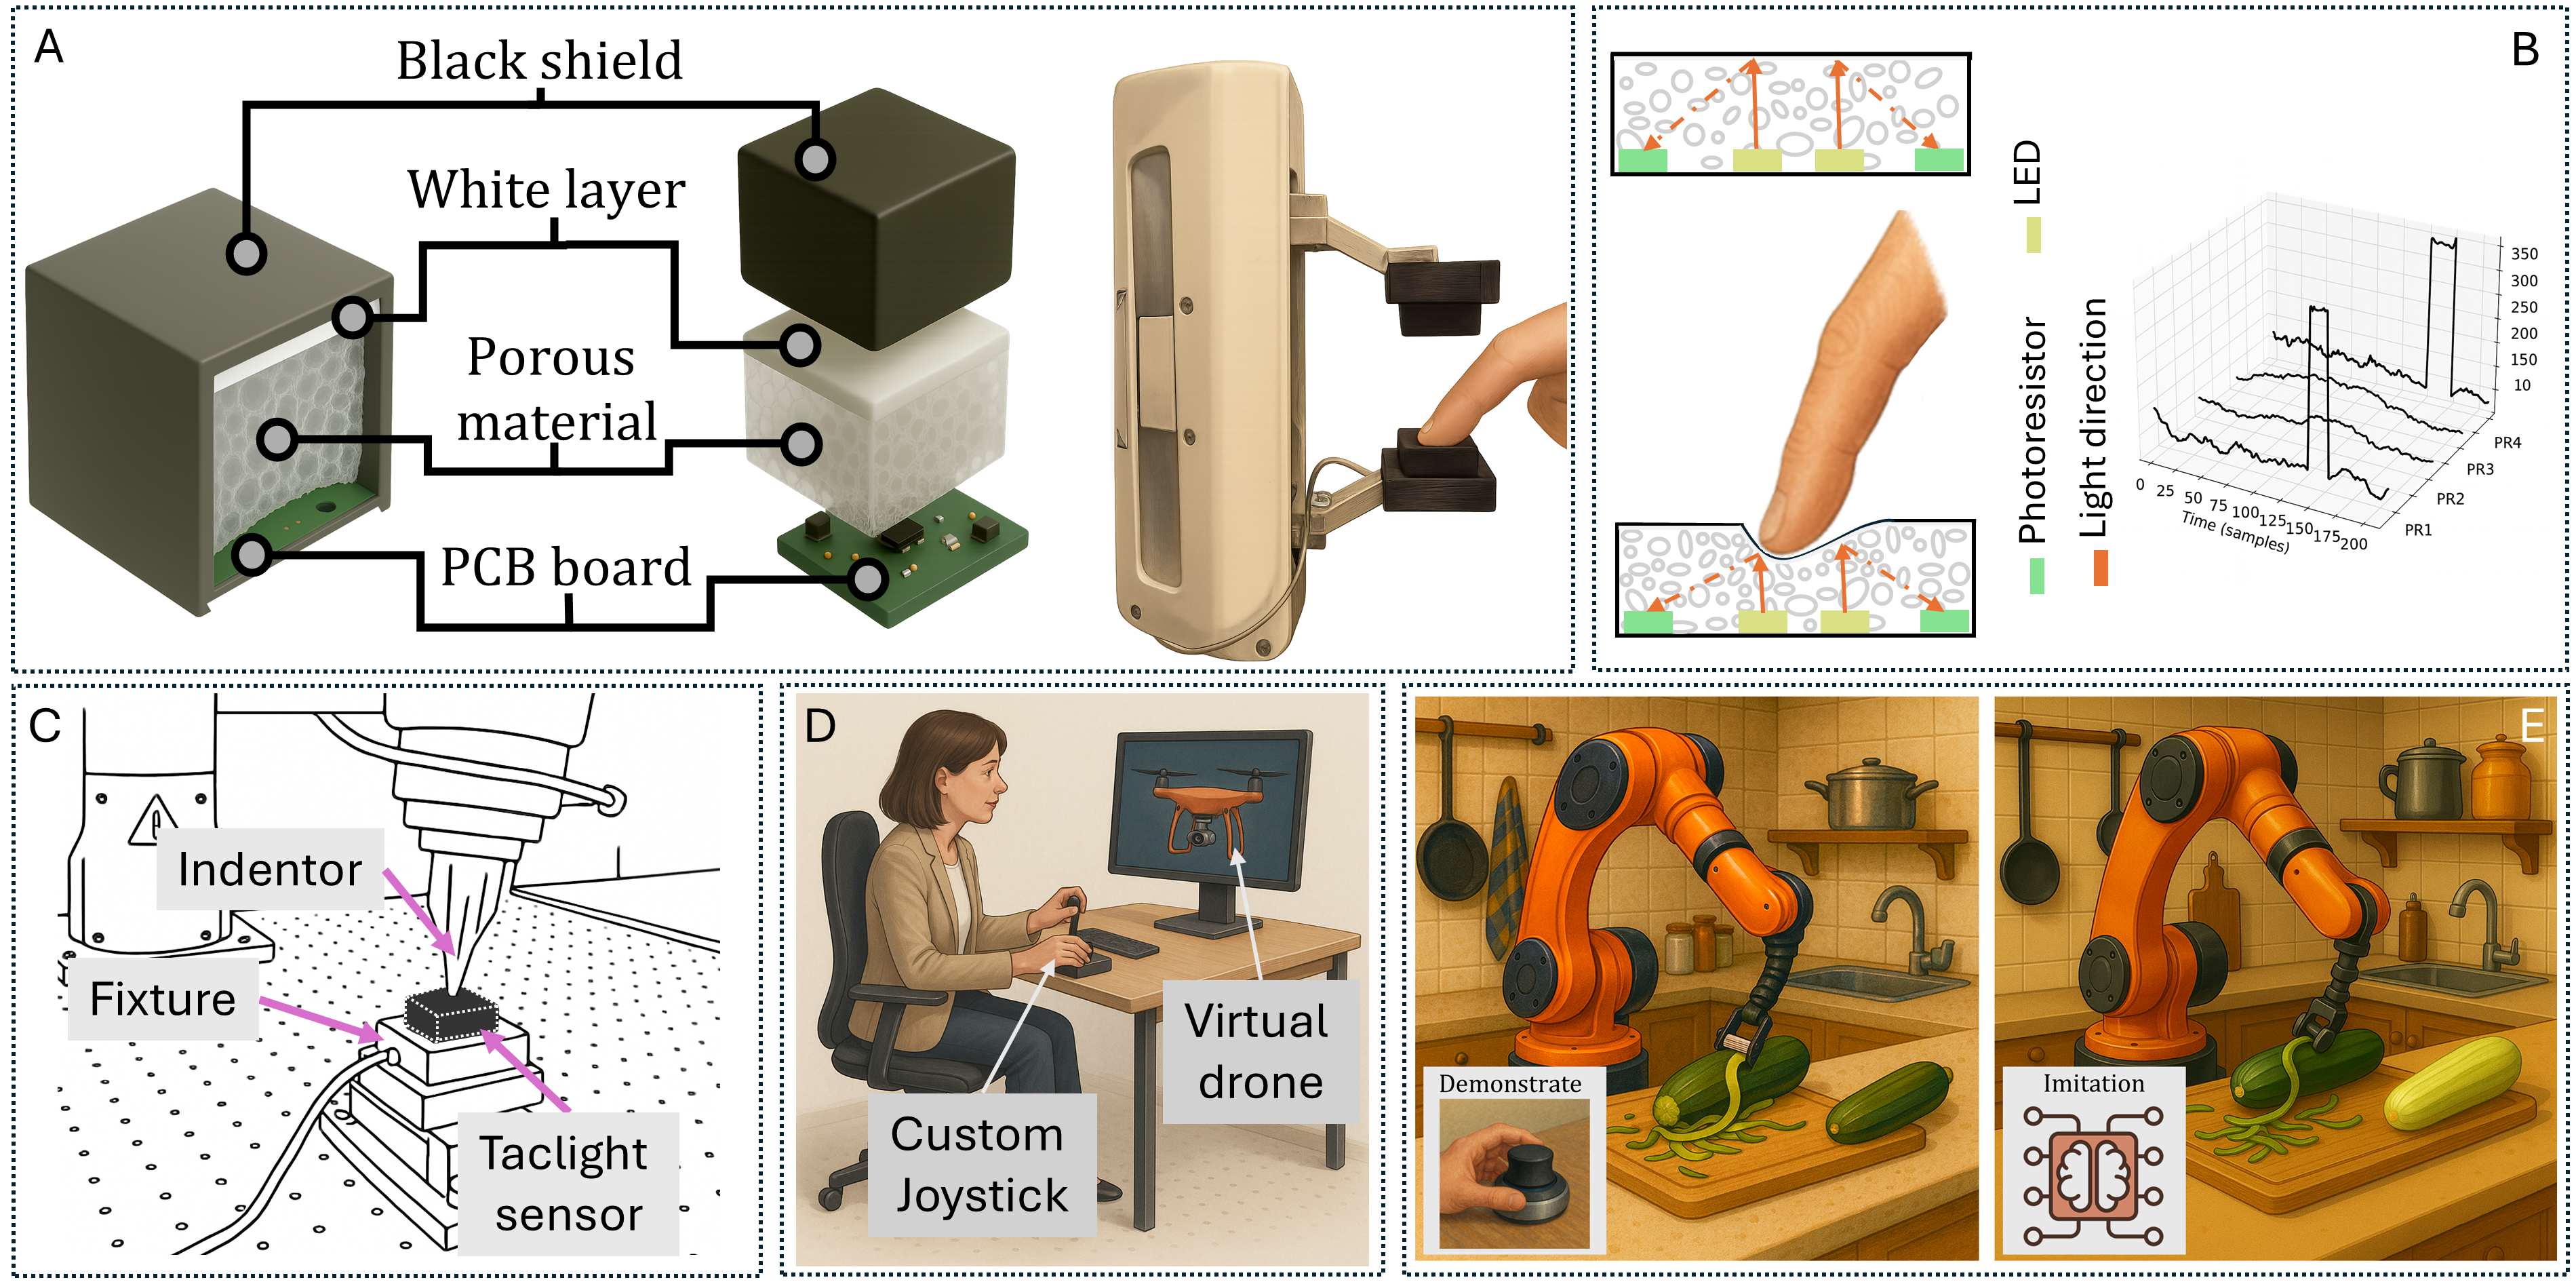
A camera-free soft optical sensor that measures six-axis forces and moments for physical and virtual interaction.
Learning through whole-arm interaction
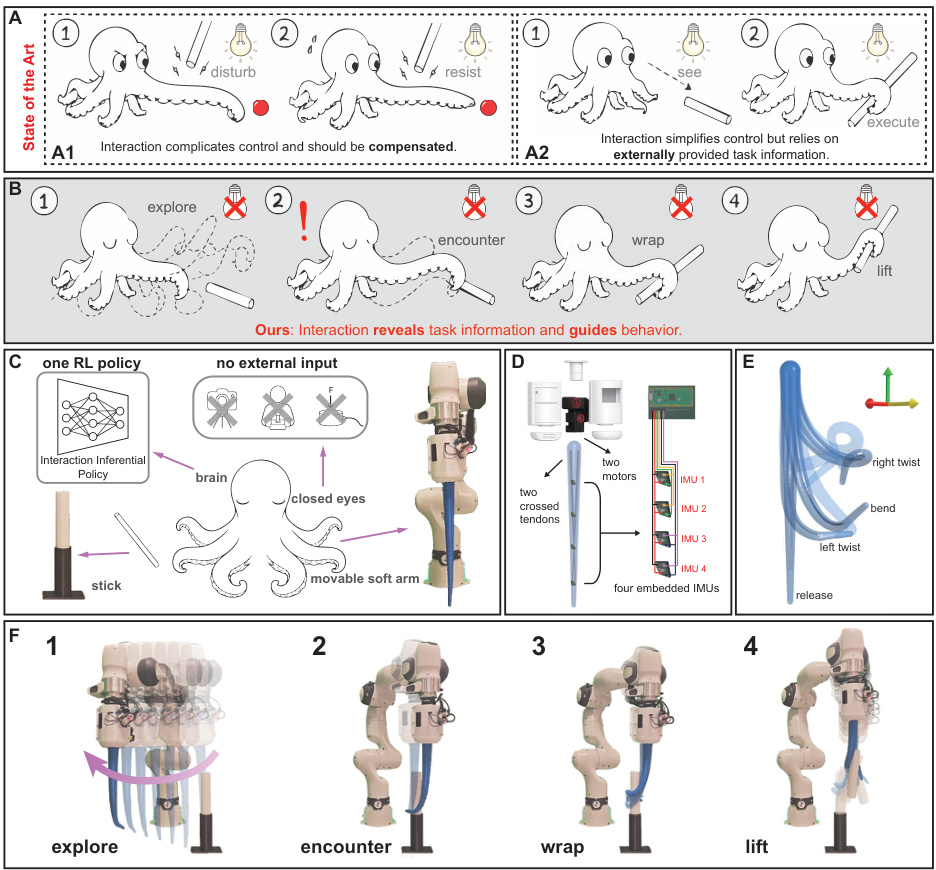
Learning to infer object properties and coordinate grasping through distributed contact along a soft robotic arm.
SENSE-STEP: sensory-enabled soft locomotion
Learning locomotion policies for a soft quadruped robot, using sensory feedback to support transfer from simulation to physical hardware.
Neural Linear Oscillator Networks
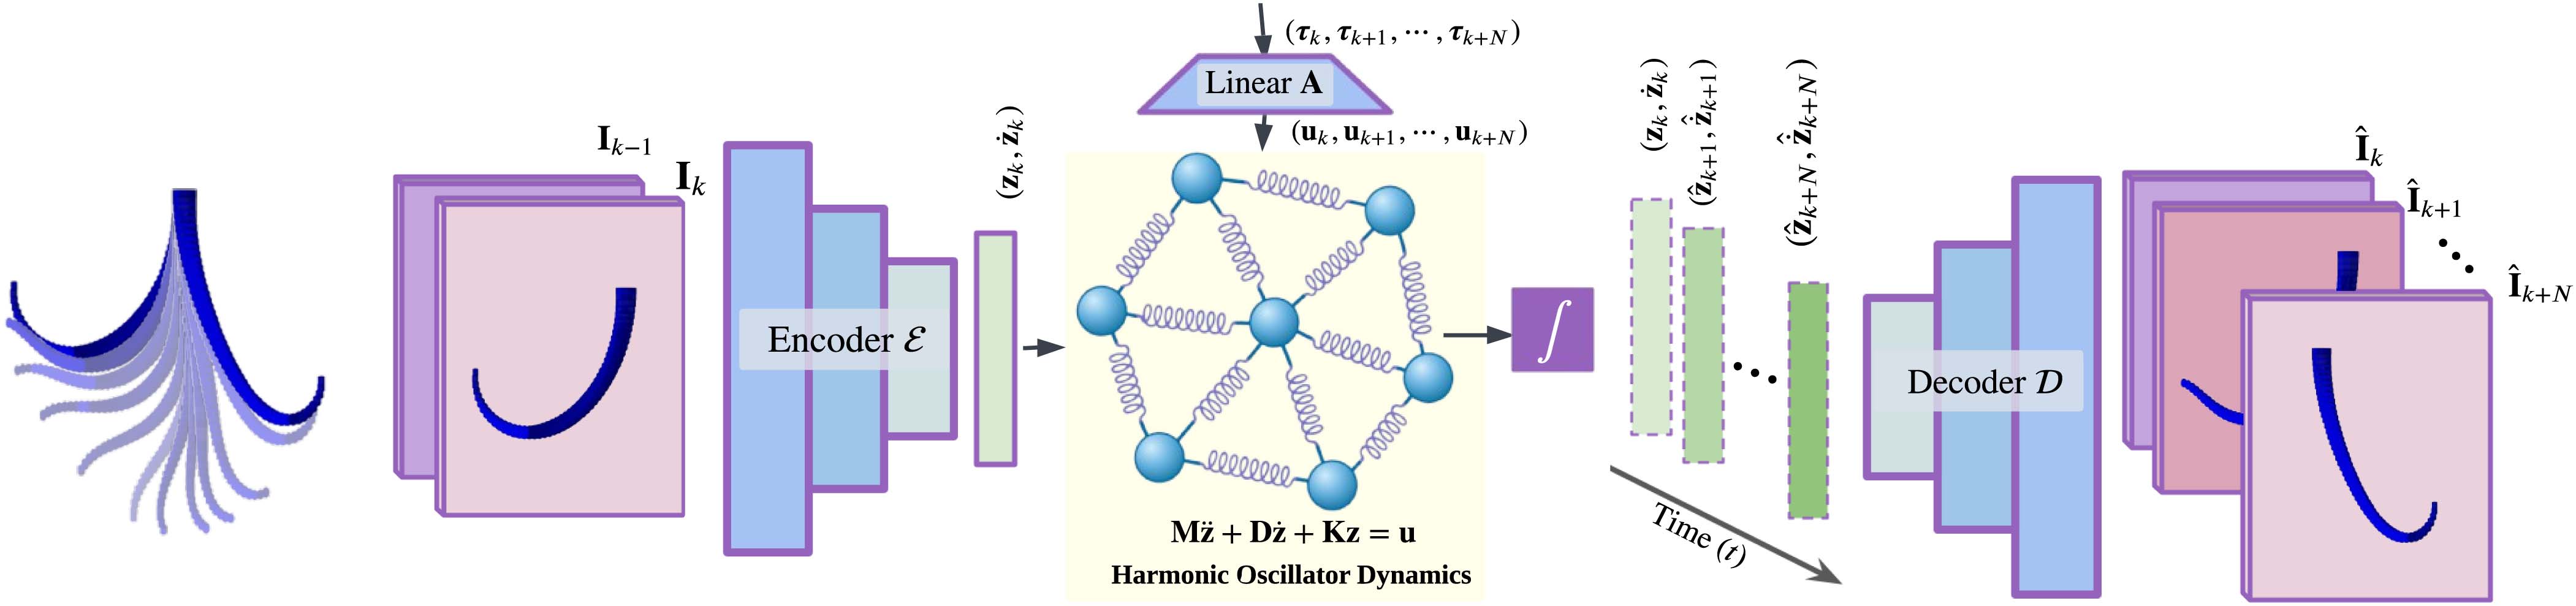
Learning models of soft-robot dynamics with neural oscillator networks for prediction and control.
Learning-based control of a soft prosthetic wrist
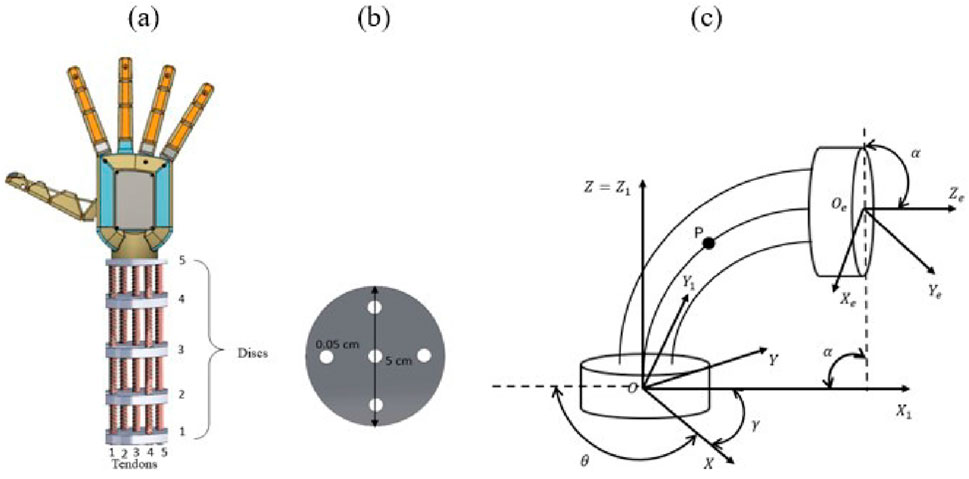
Investigating learning-based impedance control in joint space for a soft prosthetic wrist.
Reconfigurable soft gripper
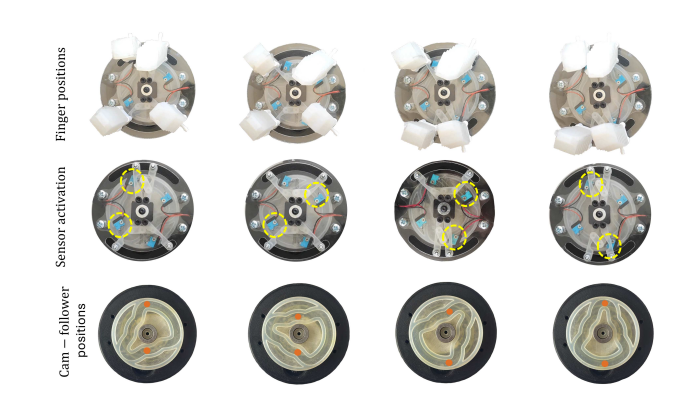
A single-motor mechanism repositions soft fingers into different grasping configurations, with sensors tracking the mechanism’s position.
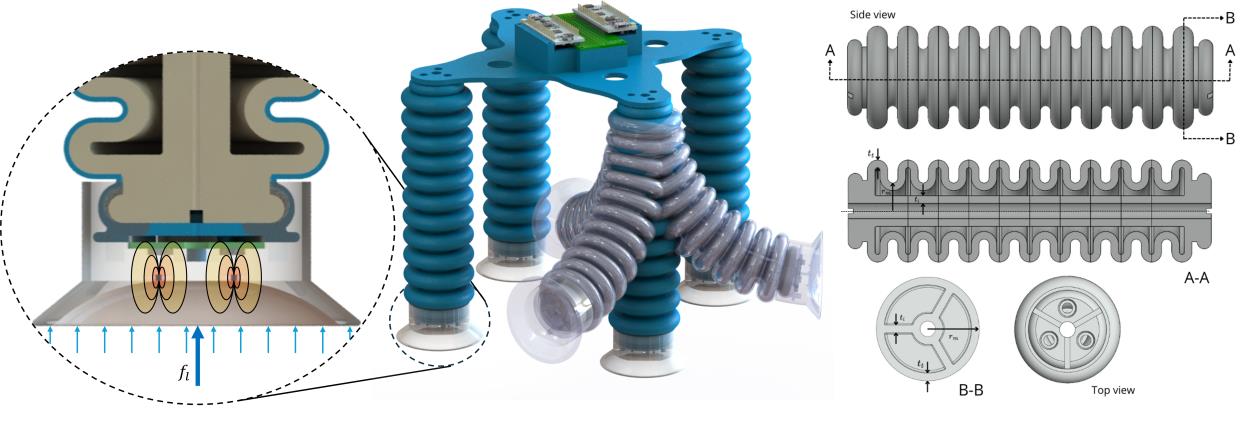
Sensorized Suction Cup for Blind Grasping

Sensorized suction cups gather information about objects during contact, supporting blind grasping and the study of preload and object stiffness.
Two Oblique Chambers Soft Pneumatic Actuators

Soft pneumatic actuators with oblique chambers generate coupled bending and twisting motions for adaptable grasping.
Soft-Rigid Robot + Imitation Learning
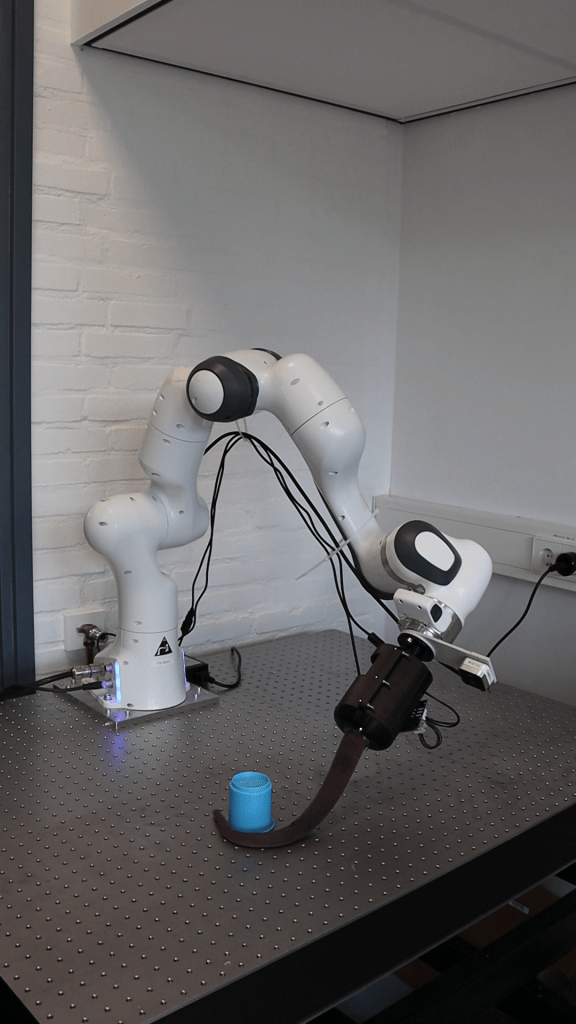
Combining soft and rigid robotics with imitation learning to perform tasks involving sustained contact.
BerryTwist: a Soft Gripper for Blackberry Harvesting
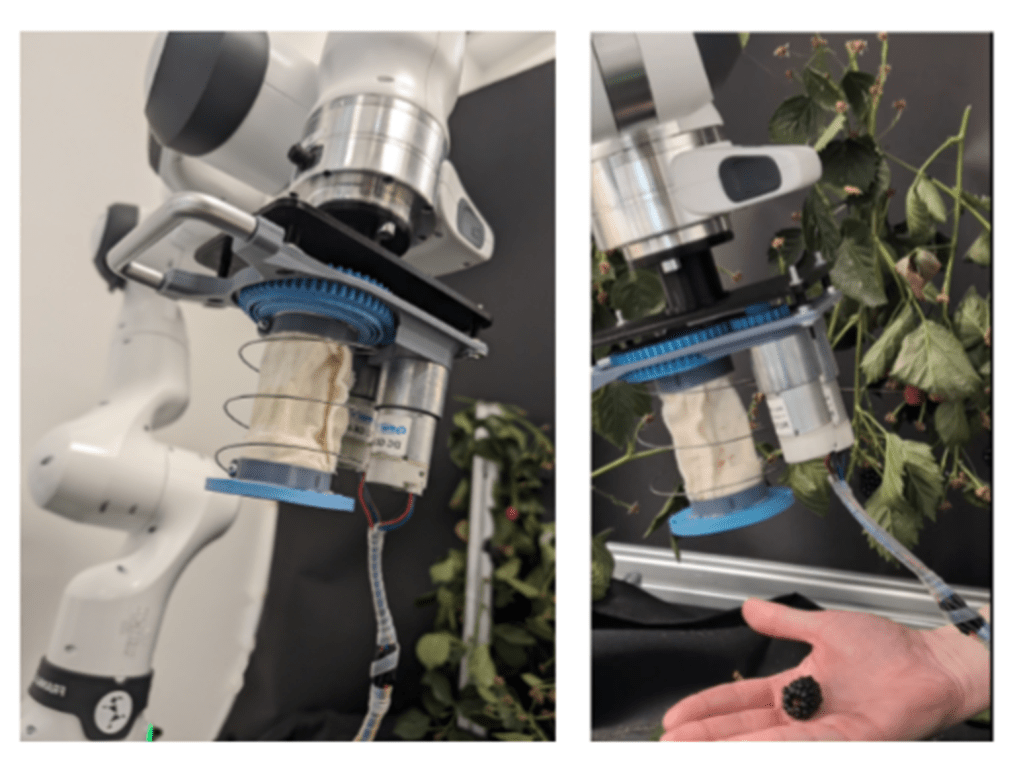
A twisting-tube soft gripper designed for handling and harvesting blackberries.
Light-Driven Silicone Actuators
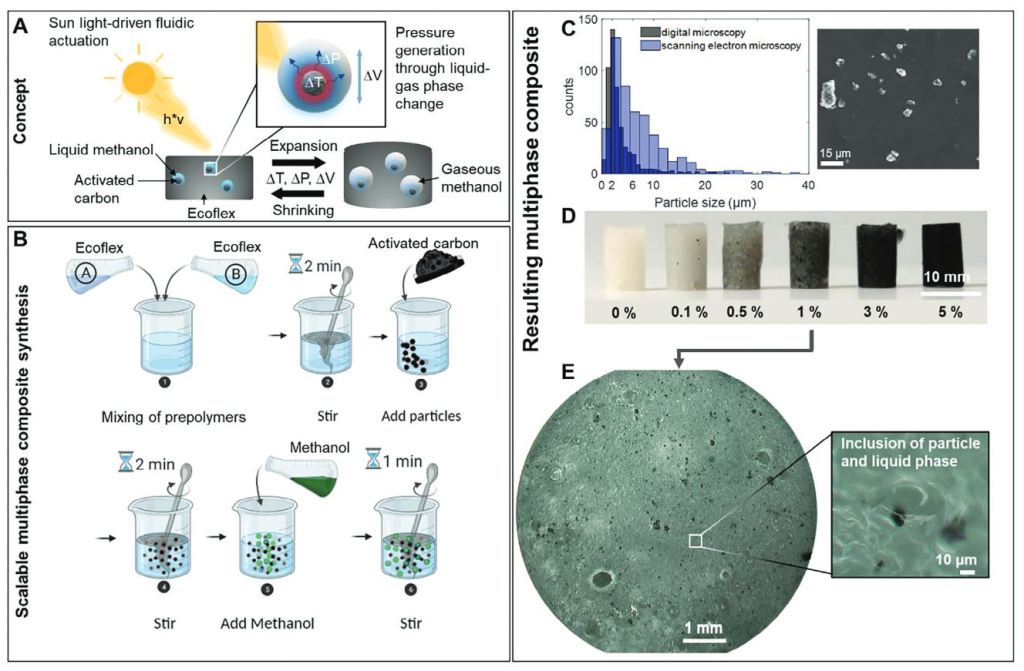
Silicone-based fluidic actuators that convert light into mechanical motion.
3D Printable Variable Stiffness Lattice Robotic Fingers
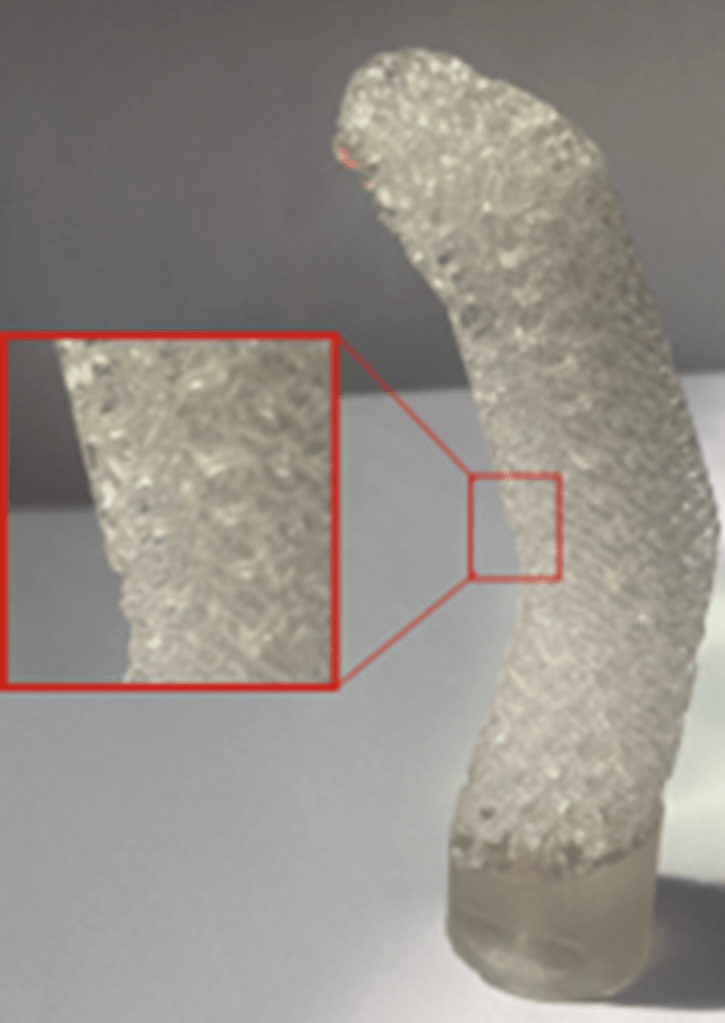
3D-printed lattice structures provide spatially varying stiffness for robotic fingers and grippers.
Parallel Cable-Driven System as a Lightweight Prosthesis
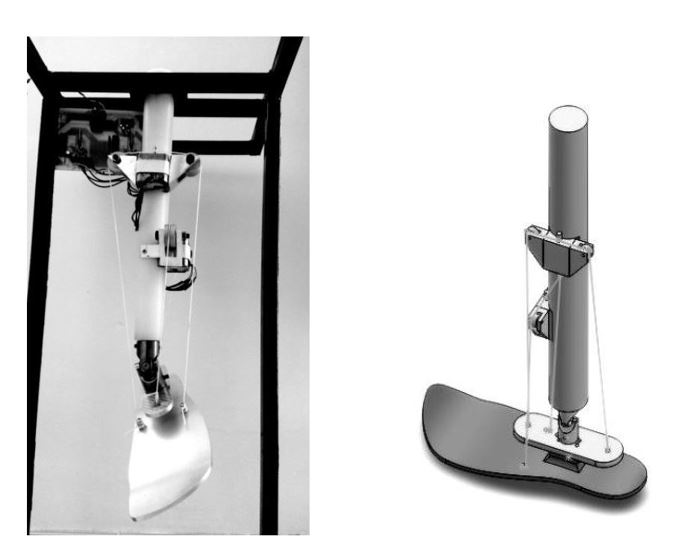
Kinematic design of a lightweight parallel cable-driven mechanism for an artificial leg.

